Summary:
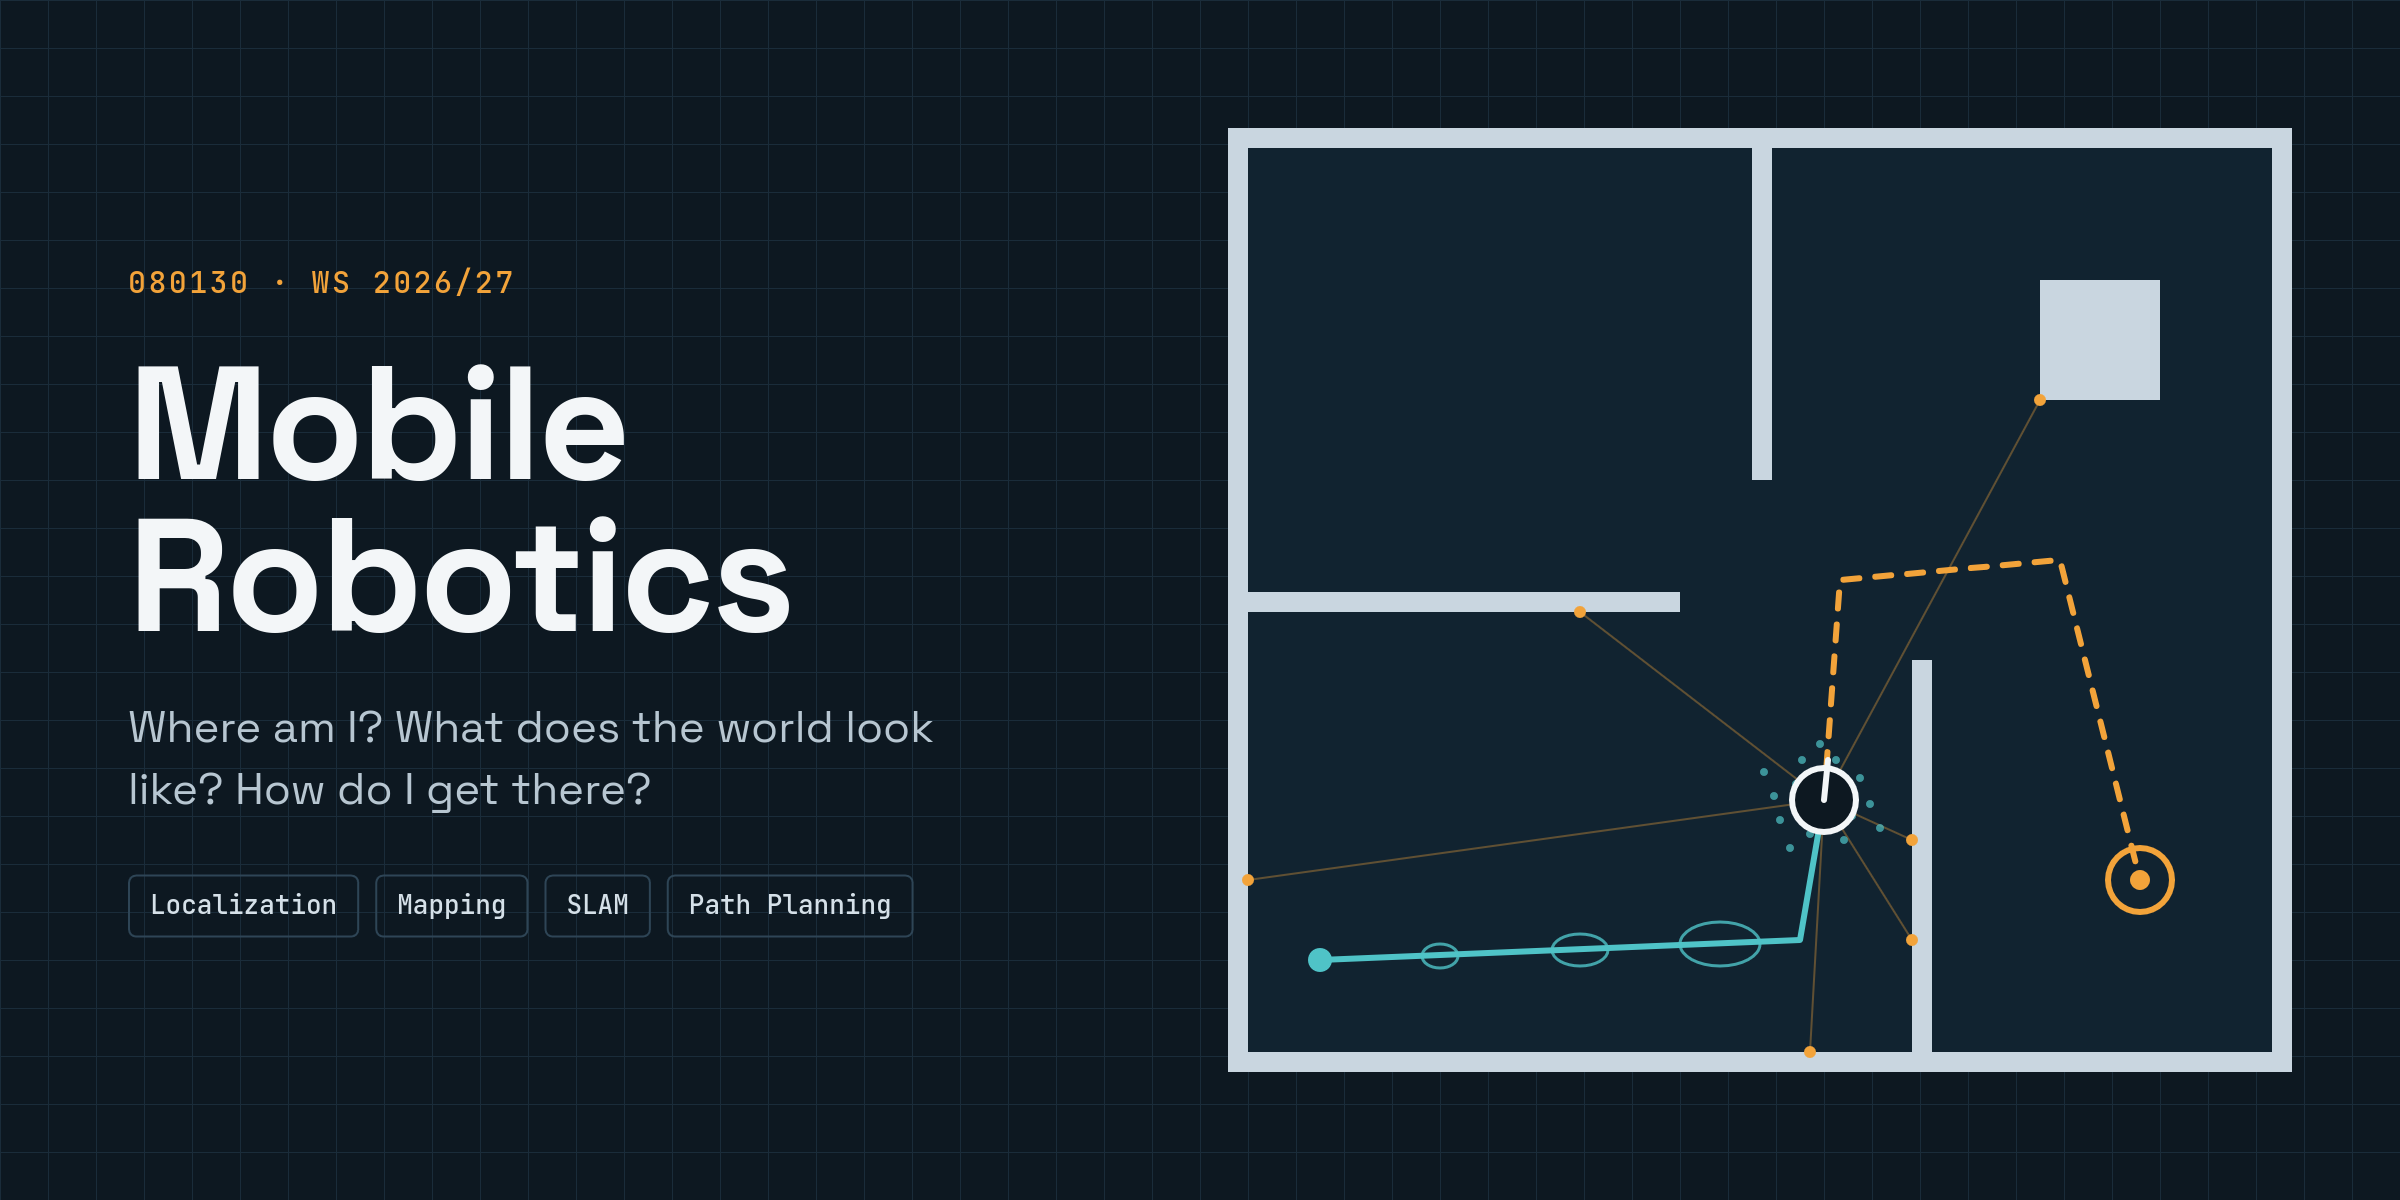
This course will introduce the key challenges, basic concepts and techniques connected to the field of mobile robotics. As robot perception is uncertain, key tasks involve estimating and representing the robot's state (e.g. its current position) and the surrounding's state (e.g. a map of the world) using probabilistic approaches, as well as techniques (e.g. path planning) to reach a goal.
Learning Objectives:
Students will understand the key challenges for mobile robots and will be able to summarize general concepts how to deal with them. They will understand and be able to apply theoretical and practical representations of uncertainty as well as motion models and filtering techniques for state estimation based upon sequential measurements and concepts for path planning and exploration. Students will be able to transfer the concepts derived to other types of robotic perception applications.
Course Content:
This course will introduce the key challenges, basic concepts and techniques connected to the field of mobile robotics. As robot perception is uncertain, key tasks involve estimating and representing the robot's state (e.g. its current position) and the surrounding's state (e.g. a map of the world) using probabilistic approaches, as well as techniques (e.g. path planning) to reach a goal. Topics include
- Kinematics
- Sensors
- Vehicle localization
- Map building
- SLAM (Simultaneous Localization and Mapping)
- Path planning
The class will follow the approaches described in the book Probabilistic Robotics, see also http://probabilistic-robotics.org/ .
Further Prerequisites:
Basic knowledge of linear algebra (equation systems, matrix multiplications) and probability is expected. There will be a repetition of the key concepts at the start of the semester though.
Examination:
Teaching and Learning Methods:
Lectures and exercises.
Literature:
Thrun, Burgard, Fox: "Probabilistic Robotics", see e.g. http://probabilistic-robotics.org/
This book is available inside the university network (e.g. vpn) via https://ebookcentral.proquest.com/lib/christianalbrechts/detail.action?docID=6246533
Comments:
This module is an extension of the module "Probabilistic Robotics". Because of the large thematic overlap, this module ("Mobile Robotics") cannot be combined with the earlier module "Probabilistic Robotics" (winter term 2023/2024). Only one of them can be considered as an elective module.